Real PD Controller
The real PD controller is designed for phase-lead compensation. It is used if the transient response is insufficient or if the system is unstable (provides a phase increase of 0 ° to 90 ° ). It is not used if the system itself does not have an integral characteristic.
The real implementation of the PD controller has similar effects as the ideal PD controller, but it is easy to implement and keeps the noise within tolerable limits.
Functions
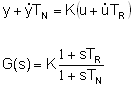
TN < TR
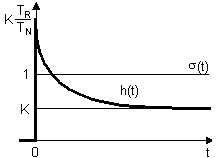
Step response
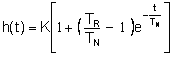
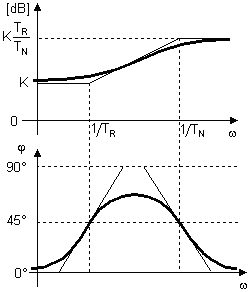
Magnitude and phase response
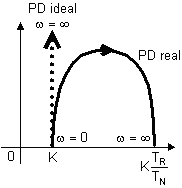
Polar plot