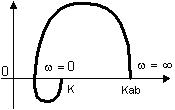Lead/Lag Controller
PID control structures are used if the steady-state or the transient performance of the controlled system are insufficient.
This controller corresponds to the modified PID controller, where the separation into a lead and a lag is particularly obvious. It does not contain a pure integrator.
Functions
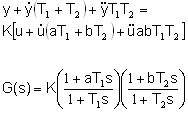
T1 < T2
a > 1
b < 1
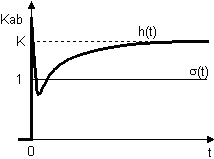
Step response
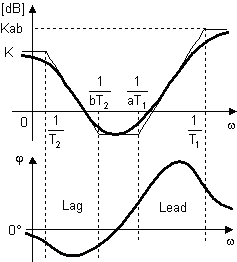
Magnitude and phase response
Polar plot