Linear Difference Equations System
SimApp lets you model linear and time-invariant difference equation systems in State Space format. This representation is particularly useful for models with a lot of interactions and for advanced control applications.
This element is the counterpart to the analog implementation. Note that the coefficients used in the difference equation system are NOT the same as for the analog implementation.
Vector form
| System matrix equation: | 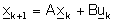 |
| Output matrix equation: | 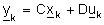 |
where: 
The system consists of n states, p input quantities and q output quantities.
|  | State vector (nx1) |
|  | Input vector (px1) |
|  | Output vector (qx1) |
| A | System matrix (nxn) |
| B | Input matrix (nxp) |
| C | Output matrix (qxn) |
| D | Direct transmission matrix (qxp) |
Matrix representation
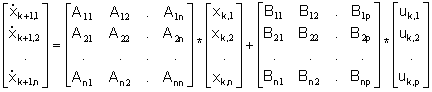
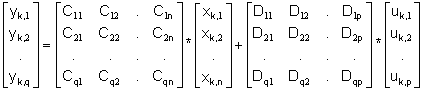
In real systems, the direct transmission matrix D usually is 0.