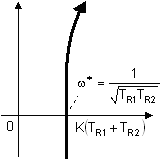Ideal PID Controller, Type 2
PID control structures are used if the steady-state and the transient performance of the system are not within specifications.
The second form of the ideal PID controller comes from the importance of the poles and zeros. The assignment of the parameters to ideal basic elements is not as obvious as for the type I controller.
Functions
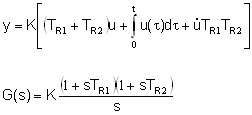
TR1 ≥ TR2
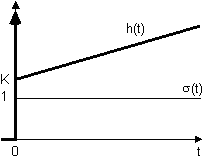
Step response
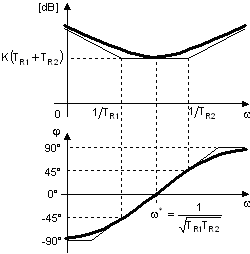
Magnitude and phase response
Polar plot