Real PID Controller
The real PID controller lessens the influence of the differentiator in the high frequency range (noise) and can be implemented easily.
Functions
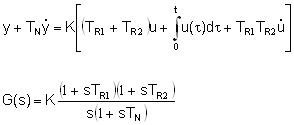
TR1 ≥ TR2 > TN
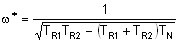
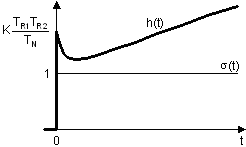
Step response
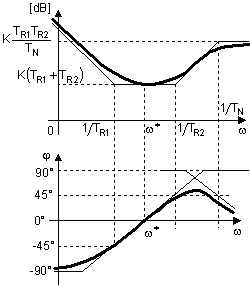
Magnitude and phase response
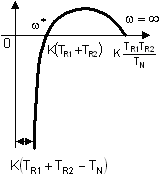
Polar plot
The real PID controller lessens the influence of the differentiator in the high frequency range (noise) and can be implemented easily.
Functions
TR1 ≥ TR2 > TN
Step response
Magnitude and phase response
Polar plot